7 Tips for Choosing the Right Manipulator Arm?

Time:2026-10-01 Author:Oliver
0%

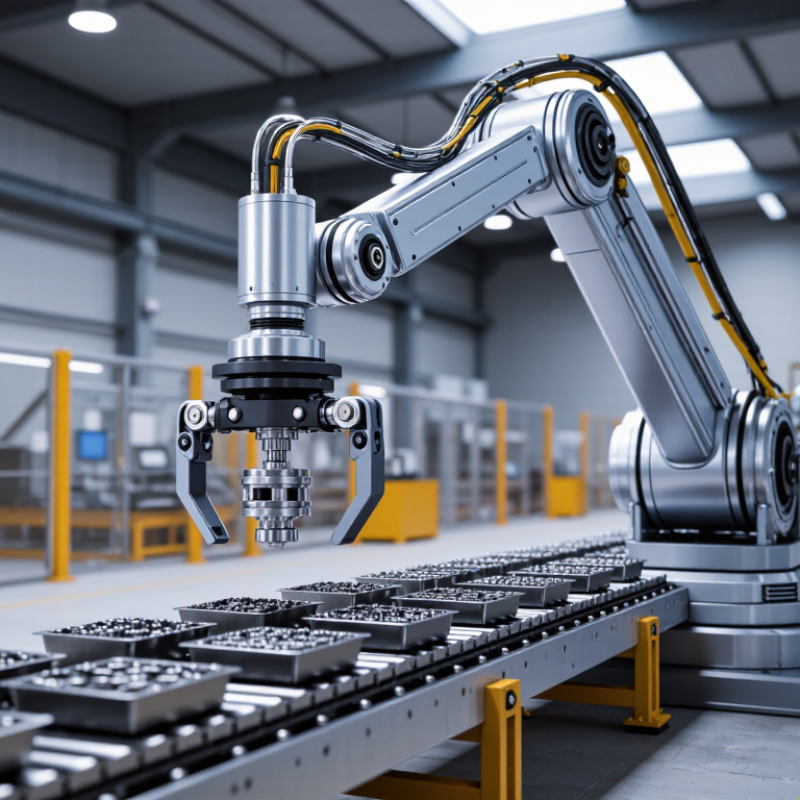
Choosing the right Manipulator Arm is not a simple matter of comparing payload ratings. It affects safety, cycle time, operator comfort, maintenance, and long-term production costs. A polished catalogue can hide difficult details, such as cable routing, wrist clearance, or unstable gripping during a fast pick-and-place cycle.

The International Federation of Robotics reported 541,302 industrial robots installed worldwide in 2023, with more than 4.28 million operating globally. These figures show strong automation demand, but they do not prove that every factory needs the same arm. The right choice depends on the workpiece, workspace, accuracy, speed, environment, and integration requirements. Interact Analysis has also identified continued growth in collaborative robotics, especially where flexible deployment and human-robot cooperation matter.

Robotics expert Rodney Brooks once said, “The robots are going to take your jobs, and we are not ready.” His warning remains useful, although it is not a complete buying strategy. A Manipulator Arm should support people, not merely replace motion with more motion. Watch the real task: a metal part sliding from a tray, a gripper twisting under load, or an operator reaching repeatedly into a narrow cell.

No checklist is perfect.

The following seven tips examine practical selection criteria, including payload, reach, repeatability, end-of-arm tooling, safety, programming, and service support. They also question common assumptions. Maximum speed may reduce control. A lower purchase price may create higher integration costs. Even experienced teams can overlook these trade-offs. Careful testing with representative parts remains more reliable than choosing from a specification sheet alone.
7 Tips for Choosing the Right Manipulator Arm?

Define the Application, Load, and Required Reach

7 Tips for Choosing the Right Manipulator Arm?

Choosing a manipulator arm starts with the application, not the catalog. Describe the task clearly. Is it picking, positioning, assembling, or transferring? Record cycle time, accuracy, operating temperature, and available floor space. Include the gripper, tooling, cables, and workpiece in the payload. A 10-kilogram part may create a much higher wrist load. Measure the center of gravity, too. It changes torque significantly.

Required reach must match the real workspace. Mark the nearest and farthest points on a simple layout. Check vertical access, wrist orientation, and clearance around fixtures. A long arm is not always better. It may reduce stiffness or create unwanted motion. Check the full reach envelope, including any restricted zones. Then review repeatability, speed, mounting position, and controller compatibility. These details often decide whether integration feels smooth or frustrating.

Consider the environment carefully. Dust, heat, moisture, and washdown requirements can affect material selection and protection levels. Confirm the manufacturer’s rated payload at your actual reach, speed, and acceleration. Do not rely only on the headline specification. A practical risk assessment should cover guarding, emergency stops, maintenance access, and operator interaction. Test a representative load before final approval. Small differences in grip force can change results. I have seen planning fail because the tool weight was forgotten. That mistake is easy to prevent, but it still happens. Choose the arm that meets today’s application while leaving sensible capacity for tomorrow.

Match the Arm’s Degrees of Freedom to the Required Movements

7 Tips for Choosing the Right Manipulator Arm?

Match the Arm’s Degrees of Freedom to the Required Movements

Degrees of freedom determine how an arm can move, rotate, and position a tool. Count the movements your process truly needs. A pick-and-place task may require three linear movements and one wrist rotation. A complex assembly may need six or more independent movements.

Imagine lifting a metal part from a tray, turning it 90 degrees, and inserting it into a narrow fixture. The arm must reach the part, control its height, and orient the gripper accurately. If it has too few degrees of freedom, the wrist may approach from an awkward angle. Operators might then redesign the fixture, which adds time and cost.

More freedom is not always better. Extra joints can increase programming effort, calibration demands, and collision risks. They may also create unnecessary movement near workers or equipment. In practical evaluations, test the full motion path with a simple mock-up. Check reach, wrist orientation, joint limits, and repeatability.

I have occasionally focused too much on maximum reach. That was a mistake. The final approach angle mattered more than the arm’s longest extension. A smaller arm with the right movement range can perform more reliably. Review real production cycles, not only catalog specifications. Ask whether each joint supports a necessary action or merely adds flexibility you may never use.

Evaluate Payload, Speed, Precision, and Operating Range

7 Tips for Choosing the Right Manipulator Arm?

Evaluate Payload, Speed, Precision, and Operating Range

Start with the real payload, not the product brochure’s maximum figure. Include the gripper, tooling, cables, and the heaviest workpiece. A safety margin matters. I usually allow extra capacity for sudden stops and uneven loads. Check the load’s center of gravity, too. A light part can still create high wrist torque.

Compare speed through the complete motion cycle. A fast joint may not produce faster production. Acceleration, settling time, and path changes often matter more. Record the required pick-and-place time beside the arm’s tested cycle time. Precision needs the same practical treatment. Separate repeatability from absolute accuracy. An arm may return to one point consistently, yet miss the programmed location. Test several positions, especially near the edge of the workspace.

Measure operating range on the actual workstation. Shelves, guards, fixtures, and nearby equipment can remove useful reach. Confirm the arm can approach from the needed angle without twisting cables or colliding with structures. Consider dust, temperature, washdown exposure, and floor vibration. These details affect precision and service life. Ask for maintenance intervals, calibration procedures, and training requirements. Reliability includes support after installation. I have seen teams overvalue speed and regret weak payload data later. No calculation is perfect. Leave time for a physical trial, because the spreadsheet can hide awkward motion.

Check Compatibility, Safety Features, and Ease of Integration

Choosing the right manipulator arm starts with compatibility, not appearance. Confirm the payload, reach, working speed, and center of gravity against your real workpiece. A small mismatch can cause vibration, inaccurate placement, or early wear. Measure the mounting surface carefully, including bolt patterns, available clearance, and cable routing. Check the arm’s control interface and communication protocols before ordering. Integration becomes expensive when basic connections are treated as an afterthought.

Safety features deserve practical testing. Look for emergency stops, protective limits, overload detection, guarded motion zones, and controlled restart functions. Match these features to your workplace risk assessment and applicable safety requirements. Ask how the arm behaves after power loss. Does it stop predictably? Can an operator release the load safely? These questions matter more than impressive cycle-time figures. Test sensors with gloves, dust, and uneven lighting, because clean demonstrations can hide weak points.

Consider the operating environment, utilities, maintenance access, and staff training. Confirm temperature, moisture, dust exposure, air pressure, electrical supply, and available floor space. Choose an arm that technicians can inspect without dismantling half the cell. Request manuals, service intervals, spare-part information, and integration support in writing. I have seen projects overlook cable bend radius, then discover damaged wiring within weeks. My own planning is not flawless either. A pilot installation often reveals assumptions that spreadsheets miss. Leave room for adjustment, document every interface, and involve operators before final approval.

7 Tips for Choosing the Right Manipulator Arm: Check Compatibility, Safety Features, and Ease of Integration
Tip Selection Dimension What to Check Practical Evaluation Guidance Required Evidence Before Purchase
1 Payload and Load Balance Confirm the rated payload includes the workpiece, gripper, tooling, adapters, and any cable or hose forces. Check the allowable wrist moment and center-of-gravity limits. Select an arm that exceeds the calculated maximum working load rather than operating continuously at its nameplate limit. Recalculate the load when the tool or workpiece changes.
Compatibility Check
Payload chart, wrist-moment data, center-of-gravity limits, tool mass, workpiece mass, and a documented load calculation.
2 Reach, Workspace, and Mounting Compare the arm's maximum reach and joint travel with the full work envelope, including fixture height, approach angle, machine doors, conveyors, and maintenance access. Verify every required pick-and-place point in a layout or simulation. Include clearance for cables, guarding, tooling changes, and operator access instead of checking reach in a straight line only. CAD model or layout drawing, mounting-hole pattern, base-load requirements, reach diagram, collision study, and installation clearances.
3 Motion Performance and Accuracy Review cycle time, maximum and rated speed, repeatability, acceleration limits, positioning accuracy, and the effect of payload on performance. Test the complete motion sequence with the real load and tooling. Use repeatability data for repetitive positioning tasks, while recognizing that accuracy also depends on calibration, fixture quality, and environmental conditions. Published repeatability specification, cycle-time study, sample program, payload-dependent speed data, and acceptance-test results using representative parts.
4 Safety Features and Risk Controls Identify emergency-stop capability, protective stopping, safe speed or force limiting where applicable, guarding interfaces, safety-rated inputs and outputs, and restart prevention. Treat safety as a system-level requirement. Complete a risk assessment covering crushing, trapping, unexpected motion, tool release, dropped loads, access points, and recovery after a stop. Safety function data, wiring diagrams, stop-category information, safety-controller compatibility, risk-assessment records, manuals, and applicable conformity documentation.
5 Environmental Suitability Match the arm's protection rating and materials to dust, moisture, washdown, temperature, cleanroom requirements, chemicals, vibration, and available floor space. Confirm that the protection rating applies to the complete installed assembly, including connectors, dress packs, grippers, and control equipment. Check operating and storage temperature ranges separately. IP or equivalent enclosure rating, temperature range, cleanroom classification if needed, chemical-compatibility information, vibration limits, and installation restrictions.
6 Ease of Integration Review available communication interfaces, digital and analog I/O, safety I/O, controller architecture, programming tools, robot-language support, and compatibility with the existing PLC or cell controller. Prefer documented interfaces and standard industrial communication options already supported by the production line. Confirm signal timing, data formats, diagnostics, remote access rules, and change-management requirements. Interface manual, I/O list, communication-protocol documentation, sample code, electrical schematics, software licensing terms, and integration test plan.
7 Maintenance, Training, and Total Cost Consider preventive-maintenance intervals, lubrication requirements, spare parts, diagnostic tools, mean time to repair, training needs, energy consumption, and service availability. Compare the complete lifecycle cost rather than purchase price alone. Include installation, tooling, programming, validation, operator training, downtime, consumables, software, and planned replacement parts. Maintenance schedule, spare-parts list, troubleshooting guide, training scope, warranty terms, service response targets, energy data, and total-cost-of-ownership estimate.

Compare Total Cost, Maintenance Needs, and Supplier Support

7 Tips for Choosing the Right Manipulator Arm

Total cost extends far beyond the purchase price. Include tooling, installation, training, energy use, spare parts, and planned downtime. The International Federation of Robotics reported 541,302 industrial robot installations in 2023, with 4.28 million robots operating worldwide. This growth increases supplier demand, but service quality still varies.

Ask for a five-year ownership estimate. Compare warranty coverage, travel charges, response times, and software support. Maintenance records should show inspection intervals, replacement-part prices, and common failure points. The U.S. Department of Energy’s Operations and Maintenance Best Practices Guide links preventive maintenance with lower repair costs than reactive work. However, projected savings can look too optimistic without your own production data.

Support matters daily. Request technician certification details, remote diagnostic procedures, and local spare-part availability. A practical trial should measure cycle time, operator comfort, positioning accuracy, and recovery after a simulated fault. Deloitte’s 2023 Smart Manufacturing and Operations Survey found that 86% of manufacturing leaders viewed smart manufacturing as important for competitiveness. That does not guarantee a good purchase. I have seen teams overvalue advanced features and underestimate training hours. Check the boring details. A cheaper arm may become expensive when one sensor requires a long overseas shipment.

FAQS

What should I define before choosing a manipulator arm?

Describe the task clearly: picking, positioning, assembling, or transferring. Record cycle time, accuracy, temperature, and floor space. Start with the application.

How should I calculate the required payload?

Include the workpiece, gripper, tooling, cables, and attachments. A 10-kilogram part can create a much higher wrist load. Measure the center of gravity carefully.

How do I choose the correct arm reach?

Mark the nearest and farthest workspace points on a simple layout. Check vertical access, wrist orientation, fixtures, and restricted zones. Longer is not always better.

Why does the arm’s final approach angle matter?

The gripper may need to enter a narrow fixture at a specific angle. Maximum reach cannot solve every positioning problem. I once focused too much on extension.

How many degrees of freedom does the arm need?

Count the movements the process truly requires. A basic pick-and-place task may need three linear movements and one wrist rotation. Complex assembly may need six or more.

Can extra degrees of freedom improve performance?

Sometimes, but extra joints can increase programming, calibration, and collision risks. Test the complete motion path with a simple mock-up. More flexibility may become clutter.

Which environmental conditions should I check?

Review dust, heat, moisture, and washdown requirements. Confirm protection levels and suitable materials. A clean-looking workspace can still hide moisture problems.

What should I test before final approval?

Test a representative load at the real reach, speed, and acceleration. Check repeatability, grip force, clearance, and operator interaction. Small differences matter.

What safety and integration details are important?

Review guarding, emergency stops, maintenance access, mounting position, and controller compatibility. Leave sensible capacity for future tasks. That part is easy to forget.

Conclusion

Choosing the right Manipulator Arm begins with a clear understanding of the intended application. Define the materials or tools it will handle, the maximum load, the required reach, and the workspace limitations. The arm’s degrees of freedom should match the movements needed, whether they involve simple positioning, rotation, angled access, or complex multi-directional tasks. Selecting an appropriate configuration helps improve efficiency while avoiding unnecessary complexity.

Next, evaluate payload capacity, operating speed, positioning precision, and working range to ensure reliable performance. Check whether the arm can integrate with existing equipment, control systems, and tooling, while also reviewing safety features such as emergency stops, protective limits, and safe motion control. Finally, compare the total cost of ownership, including installation, maintenance, training, energy use, and replacement parts. Responsive supplier support, clear documentation, and accessible service can significantly improve long-term value and reduce downtime.
Oliver

Oliver

Oliver is a seasoned marketing professional with a wealth of expertise in driving brand awareness and engagement. With a deep understanding of our company's product offerings, he consistently delivers high-quality content that enriches our professional blog. His insights not only shed light on......